Curious about the robots deployed?
Process Overview
This deployment was implemented at Yuhan-Kimberly’s Chungju Plant, delivering an integrated solution that combines a Yaskawa industrial robot with a strapping-cut workbench to automate depalletizing + strap cutting.
The customer pursued a depalletizing system to reduce labor costs and operator fatigue, and showed strong interest in automating strap cutting and strap discharge to further maximize cost savings and operational efficiency.
The solution handles mixed carton sizes by aligning (squaring) cartons, cutting and removing straps, and then feeding cartons into the case packer. This improves throughput and consistency in both carton infeed and strap removal, while reducing physical strain on operators and enhancing workplace safety.
Project Background and Objectives
At Yuhan-Kimberly’s Chungju Plant, cartons arriving on pallets were previously broken down manually and then loaded one-by-one into the case packer. The work was highly repetitive, and manual strap removal using knives created a persistent risk of safety incidents.
The objective of this project was to minimize reliance on manual labor by automating the entire process—from depalletizing through case packer infeed—and to achieve lights-out (unmanned) operation for strap cutting. This enables improved operator safety, reduced fatigue and staffing burden on the floor, and more stable, repeatable plant operations.
Components
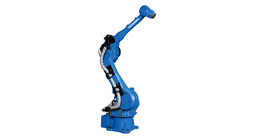
| Robot | Yaskawa GP50 Industrial Robot: A high-speed, high-precision 6-axis articulated robot optimized for palletizing/depalletizing operations. It can automatically pick, place, and transfer a wide range of products, making it well-suited for industrial automation. |
|---|---|
| Peripherals | Carton Aligner + Strap-Cutting Station: A workbench system that squares/aligns cartons of various sizes, then cuts and evacuates strapping. Safety Light Curtain + Perimeter Fence: Visually separates the operator zone from the robot cell. If an operator enters the depalletizing area, the system immediately stops motion to ensure safety. |
Workflow
| STEP 1. | An operator loads a pallet of stacked cartons into the designated loading position |
|---|---|
| STEP 2. | The operator selects the carton “recipe” on the HMI (OP panel) and starts the cycle |
| STEP 3. | The robot depalletizes bundled cartons per the selected recipe and transfers them to the alignment/strap-cutting station |
| STEP 4. | The station squares the bundle using servo drives and pneumatic cylinders |
| STEP 5. | The system cuts the straps while the cartons are securely clamped in position |
| STEP 6. | A hook mechanism captures and discharges the cut straps |
| STEP 7. | The station re-squares the bundle to prevent misalignment during cutting |
| STEP 8. | The robot feeds individual cartons to the case packer infeed one by one. |
※ The content provided by Bigwave Robotics is protected under U.S. and Canadian copyright and intellectual property laws. Unauthorized reproduction, distribution, or use of this content is strictly prohibited.
Recommended Use Cases

Faucet Assembly using Five Doosan M0609 Units
This assembly automation solution utilizes five Doosan M0609 collaborative robots to fully automate the end-to-end assembly process of faucets. Previously, this process required a large number of workers to manually assemble each unit. By integrating collaborative robots with a conveyor system, continuous production across the entire process has been achieved. The transition from a manual line (where 5 workers produced 1,000 units per day) to an automated line (where 2 workers produce 1,200 units per day) has resulted in a significant improvement in productivity.

Smartphone Transfer using TechFloor Mobile Manipulator (M6X)
This transfer automation solution utilizes the TechFloor Mobile X, a high-performance Mobile Manipulator, to pick smartphones from shelving units, load them onto its onboard platform, and transport them to the next process stage. The TechFloor Mobile X can be deployed without extensive infrastructure changes and offers flexible adaptation to layout or workstation modifications. It ensures high productivity through rapid transit and high-precision docking, minimizing common mobile robot issues such as alignment errors. By applying this solution to environments with frequent inter-process part transfers, continuous operation is achieved regardless of shifts, significantly boosting productivity without additional labor costs.

Aluminum Dross Processing using Yaskawa Robots
This automation solution utilizes YASKAWA robots to automate the hazardous manual process of handling high-temperature aluminum dross (a byproduct of molten aluminum). By deploying a robot with high heat resistance, this system replaces human operators in extreme thermal environments, ensuring workplace safety and enabling continuous, non-stop operation. The primary goal of this project was to enhance operational safety and improve the work environment by automating the byproduct treatment following high-heat aluminum processing.
Process Overview
This deployment was implemented at Yuhan-Kimberly’s Chungju Plant, delivering an integrated solution that combines a Yaskawa industrial robot with a strapping-cut workbench to automate depalletizing + strap cutting.
The customer pursued a depalletizing system to reduce labor costs and operator fatigue, and showed strong interest in automating strap cutting and strap discharge to further maximize cost savings and operational efficiency.
The solution handles mixed carton sizes by aligning (squaring) cartons, cutting and removing straps, and then feeding cartons into the case packer. This improves throughput and consistency in both carton infeed and strap removal, while reducing physical strain on operators and enhancing workplace safety.
Project Background and Objectives
At Yuhan-Kimberly’s Chungju Plant, cartons arriving on pallets were previously broken down manually and then loaded one-by-one into the case packer. The work was highly repetitive, and manual strap removal using knives created a persistent risk of safety incidents.
The objective of this project was to minimize reliance on manual labor by automating the entire process—from depalletizing through case packer infeed—and to achieve lights-out (unmanned) operation for strap cutting. This enables improved operator safety, reduced fatigue and staffing burden on the floor, and more stable, repeatable plant operations.
Components
| Robot | Yaskawa GP50 Industrial Robot: A high-speed, high-precision 6-axis articulated robot optimized for palletizing/depalletizing operations. It can automatically pick, place, and transfer a wide range of products, making it well-suited for industrial automation. |
|---|---|
| Peripherals | Carton Aligner + Strap-Cutting Station: A workbench system that squares/aligns cartons of various sizes, then cuts and evacuates strapping. Safety Light Curtain + Perimeter Fence: Visually separates the operator zone from the robot cell. If an operator enters the depalletizing area, the system immediately stops motion to ensure safety. |
Workflow
| STEP 1. | An operator loads a pallet of stacked cartons into the designated loading position |
|---|---|
| STEP 2. | The operator selects the carton “recipe” on the HMI (OP panel) and starts the cycle |
| STEP 3. | The robot depalletizes bundled cartons per the selected recipe and transfers them to the alignment/strap-cutting station |
| STEP 4. | The station squares the bundle using servo drives and pneumatic cylinders |
| STEP 5. | The system cuts the straps while the cartons are securely clamped in position |
| STEP 6. | A hook mechanism captures and discharges the cut straps |
| STEP 7. | The station re-squares the bundle to prevent misalignment during cutting |
| STEP 8. | The robot feeds individual cartons to the case packer infeed one by one. |
※ The content provided by Bigwave Robotics is protected under U.S. and Canadian copyright and intellectual property laws. Unauthorized reproduction, distribution, or use of this content is strictly prohibited.