Process Overview
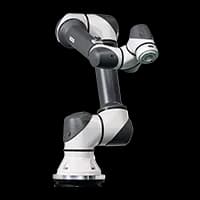
This deployment is a pick-and-place automation solution for handling steel plates on a press line, using PICKSYS 3D vision and Doosan collaborative robots(Cobots).
By combining 3D vision with cobots, the system can handle unstandardized (non-uniform) steel plates safely and efficiently. It automates tasks that operators typically avoid, improving overall operating efficiency and helping increase job satisfaction on the floor.
Warranty Period : 1 year
Project Year : 2023
Project Duration : 8 weeks
Solution design & fabrication: 4 weeks
On-site installation: 2 weeks
Stabilization: 2 weeks
Project Background and Objectives
Automate undesirable tasks to help prevent operator turnover.
Replace high-payload, repetitive work with robots to help prevent musculoskeletal injuries and workplace incidents.
Maximize efficiency in repetitive loading/unloading work using a vision system.
Components
| Robot | Doosan Robotics A0912 Payload: 9 kg Reach: 1,200 mm Pick-it L SD vision 3D camera Processor 3.0, cable set Set of three (3) region markers Robot calibration plate |
|---|---|
| Peripherals | PICKSYS frame Vacuum gripper Dedicated jig Harness OP switch |
Workflow
| STEP 1. | Steel plates are processed at the press line |
|---|---|
| STEP 2. | The 3D vision system detects each steel plate |
| STEP 3. | Detected plate data is transferred to the collaborative robot |
| STEP 4. | The cobot picks the steel plate using a vacuum gripper |
| STEP 5. | The vision system identifies the target placement position |
| STEP 6. | The cobot places the steel plate at the designated location. |
※ The content provided by Bigwave Robotics is protected under U.S. and Canadian copyright and intellectual property laws. Unauthorized reproduction, distribution, or use of this content is strictly prohibited.
Recommended Use Cases

Metal Machining Machine Tending for Three WIA MCTs using Yaskawa Robots
This machine tending automation solution utilizes a YASKAWA industrial robot to automate the loading and unloading of metal workpieces for three WIA MCT (F410D) units. In the traditional process, operators had to stand by the machines constantly to manually feed workpieces. By delegating the loading and unloading tasks to the robot, operators can now focus on overall equipment management and system operation, significantly increasing operational efficiency. Furthermore, by having a single robot service three machining centers, productivity is maximized across the entire production cell.

Steel Plate Press Assistance using Dual Yaskawa Robots
This automation solution utilizes two YASKAWA robots to assist in steel plate press operations. By automating the machine tending process, the system secures high operational stability and safety. Due to the nature of press processes—characterized by extremely short cycle times and high-risk environments—industrial accidents involving human operators are frequent. In this specific solution, the robots hold the workpieces during the pressing operation itself. By having two robots perform continuous, synchronized cross-work, the cycle time is minimized to just 2 seconds per unit, maximizing overall productivity.

Cognex AI Vision: 4-Model Review 👀 Can This 3D AI Vision Read 255 Barcodes at Once?
Introducing four AI Vision solutions showcased by Cognex at the 2026 AW (Aircraft Automation Show). From simultaneous reading of 255 barcodes and 15-minute installation to deep learning cargo classification , check them out now if you are interested in Vision automation for logistics and manufacturing sites.
Process Overview
This deployment is a pick-and-place automation solution for handling steel plates on a press line, using PICKSYS 3D vision and Doosan collaborative robots(Cobots).
By combining 3D vision with cobots, the system can handle unstandardized (non-uniform) steel plates safely and efficiently. It automates tasks that operators typically avoid, improving overall operating efficiency and helping increase job satisfaction on the floor.
Warranty Period : 1 year
Project Year : 2023
Project Duration : 8 weeks
Solution design & fabrication: 4 weeks
On-site installation: 2 weeks
Stabilization: 2 weeks
Project Background and Objectives
Automate undesirable tasks to help prevent operator turnover.
Replace high-payload, repetitive work with robots to help prevent musculoskeletal injuries and workplace incidents.
Maximize efficiency in repetitive loading/unloading work using a vision system.
Components
| Robot | Doosan Robotics A0912 Payload: 9 kg Reach: 1,200 mm Pick-it L SD vision 3D camera Processor 3.0, cable set Set of three (3) region markers Robot calibration plate |
|---|---|
| Peripherals | PICKSYS frame Vacuum gripper Dedicated jig Harness OP switch |
Workflow
| STEP 1. | Steel plates are processed at the press line |
|---|---|
| STEP 2. | The 3D vision system detects each steel plate |
| STEP 3. | Detected plate data is transferred to the collaborative robot |
| STEP 4. | The cobot picks the steel plate using a vacuum gripper |
| STEP 5. | The vision system identifies the target placement position |
| STEP 6. | The cobot places the steel plate at the designated location. |
※ The content provided by Bigwave Robotics is protected under U.S. and Canadian copyright and intellectual property laws. Unauthorized reproduction, distribution, or use of this content is strictly prohibited.
Related Use Cases
Metal Machining Machine Tending for Three WIA MCTs using Yaskawa Robots
Steel Plate Press Assistance using Dual Yaskawa Robots