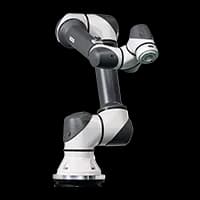
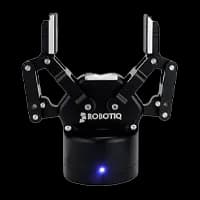
This application uses a TM5 with a built-in vision camera to accurately detect molded parts in a vertical injection molding environment, compensate for positional variation, and perform precision insert operations. Even with misalignment between the turntable and the injection molding machine, the vision camera corrects the position, enabling automated insert work.
Project Background and Objectives
Replace labor in situations where hiring is difficult
Prevent safety incidents in hazardous operations
Components
| Robot | TM5
|
|---|---|
| Peripherals |
|
Workflow
| STEP 1. | Eject the workpiece |
|---|---|
| STEP 2. | Detect the workpiece using the vision camera |
| STEP 3. | Compensate for position and insert the workpiece |
※ The content provided by Bigwave Robotics is protected under U.S. and Canadian copyright and intellectual property laws. Unauthorized reproduction, distribution, or use of this content is strictly prohibited.
Recommended Use Cases

Box Pick-and-Place Automation Solution using a Box Picker Gripper
Process Overview This deployment is a box pick-and-place automation solution using a Box Picker Gripper. As the name suggests, the Box Picker Gripper is designed to pick a wide range of objects. In this solution, it enables stable picking even when plastic boxes are open-top (without lids), improving handling reliability in box transfer operations.

Automotive Component Assembly Automation using Epson C4 + FT Sensor
Process Overview This assembly automation solution uses an Epson C4 robot and an FT (Force-Torque) sensor to automate the task of inserting and fastening automotive parts with a tight press-fit tolerance. Even when the fit is extremely tight, the system can detect insertion force, locate the correct position, and perform smooth insertion without part damage or jamming. This project was implemented to automate the insertion of fixing pins used in automotive components.

Bumper Gate Cutting and Transfer Automation using Two Yaskawa Robots
Process Overview This transfer automation solution uses two Yaskawa robots and vacuum grippers to perform gate cutting on automotive bumper injection molded parts and transfer them to a conveyor tray. The system accurately picks curved and flexible bumper parts, performs gate cutting, and applies conveyor tracking technology to load parts onto continuously moving conveyor trays. By enabling continuous operation without stoppage or idle time, the solution maintains high productivity throughout the process.
This application uses a TM5 with a built-in vision camera to accurately detect molded parts in a vertical injection molding environment, compensate for positional variation, and perform precision insert operations. Even with misalignment between the turntable and the injection molding machine, the vision camera corrects the position, enabling automated insert work.
Project Background and Objectives
Replace labor in situations where hiring is difficult
Prevent safety incidents in hazardous operations
Components
| Robot | TM5
|
|---|---|
| Peripherals |
|
Workflow
| STEP 1. | Eject the workpiece |
|---|---|
| STEP 2. | Detect the workpiece using the vision camera |
| STEP 3. | Compensate for position and insert the workpiece |
※ The content provided by Bigwave Robotics is protected under U.S. and Canadian copyright and intellectual property laws. Unauthorized reproduction, distribution, or use of this content is strictly prohibited.
Related Use Cases
Box Pick-and-Place Automation Solution using a Box Picker Gripper
Automotive Component Assembly Automation using Epson C4 + FT Sensor