Process Overview
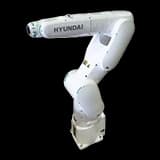
This palletizing automation solution uses the Hyundai Robotics HH050 and Mech-Mind 3D vision to detect mixed-size boxes, align them by size, and automatically stack them onto pallets. By leveraging a cost-effective 3D vision system, the cell can reliably palletize even when cartons of varying dimensions are mixed in the flow, ensuring stable operation.
Components
| Robot | Mech-Mind Mech-Eye Laser L (Industrial 3D camera) FOV: 1250 × 1460 @ 1.5 m; 2500 × 2890 @ 3 m Resolution: 2048 × 1536 (3 MP) Accuracy: 1.0 mm @ 2 m Scan time: 0.9–1.3 s Recommended scanning distance: 1.5–3 m Mech-Viz Intelligent Programming Environment: robot programming tool Hyundai Robotics HDR50-22 (HH050) Repeatability: ±0.06 mm |
|---|---|
| Peripherals | Tooling Vacuum gripper 3D Vision Mech-Eye Laser L (FOV: 1250 × 1460 @ 1.5 m; 2500 × 2890 @ 3 m, Resolution: 2048 × 1536 (3 MP), Accuracy: 1.0 mm @ 2 m, Scan time: 0.9–1.3 s, Recommended scanning distance: 1.5–3 m, Mech-Viz Intelligent Programming Environment: robot programming tool) Peripheral Equipment Robot base Vision mounting stand Box infeed stand Pallet fixing guide |
Workflow
| STEP 1. | Scan available pallet stacking space using 3D vision |
|---|---|
| STEP 2. | Pick each box and place it into the remaining pallet space based on its size |
| STEP 3. | Repeat until palletizing is complete |
※ The content provided by Bigwave Robotics is protected under U.S. and Canadian copyright and intellectual property laws. Unauthorized reproduction, distribution, or use of this content is strictly prohibited.
Recommended Use Cases

Product Sorting Automation using UR5 and Deep Learning
This next-generation sorting solution leverages 3D Vision, Deep Learning (Instance Segmentation), Reinforcement Learning, and Motion Planning (OMPL) to automate complex tasks such as product classification, assembly, and packing. By utilizing cost-effective 3D vision, the system recognizes the type and location of products and bins in real-time. This allows the robot to automatically compensate for shifts in the position of items or boxes without manual intervention. The integration of Motion Planning drastically reduces human teaching time, while Reinforcement Learning optimizes movements to minimize overall cycle times.

Steel Plate Press Assistance using Dual Yaskawa Robots
This automation solution utilizes two YASKAWA robots to assist in steel plate press operations. By automating the machine tending process, the system secures high operational stability and safety. Due to the nature of press processes—characterized by extremely short cycle times and high-risk environments—industrial accidents involving human operators are frequent. In this specific solution, the robots hold the workpieces during the pressing operation itself. By having two robots perform continuous, synchronized cross-work, the cycle time is minimized to just 2 seconds per unit, maximizing overall productivity.

Automation Success at UK Parts Supplier! 🦾 Field Reveal of an Automated Warehouse Powered by 40 AMRs 😎
Process Overview L&S Engineers, one of the UK's largest suppliers of spare parts and consumables, implemented HIK's logistics robot solution to enhance logistics efficiency in its large-scale warehouse. This project focused on automating the order picking process using mobile robots, increasing logistics precision, and reducing the physical burden on workers. Project Background & Objectives Background L&S Engineers operates a massive logistics center that handles thousands of spare parts and consumables, processing a high volume of orders daily. However, the existing manual methods faced several challenges: High worker fatigue due to long walking distances. Low operational efficiency and slow order processing speeds. Concerns over decreased customer satisfaction due to high error rates. Objectives Enhance Operational Efficiency: Reduce worker travel distances and improve productivity through mobile robots. Improve Accuracy: Decrease error rates in the order picking process. Reduce Operational Costs: Lower labor and operating expenses through automation.
Process Overview
This palletizing automation solution uses the Hyundai Robotics HH050 and Mech-Mind 3D vision to detect mixed-size boxes, align them by size, and automatically stack them onto pallets. By leveraging a cost-effective 3D vision system, the cell can reliably palletize even when cartons of varying dimensions are mixed in the flow, ensuring stable operation.
Components
| Robot | Mech-Mind Mech-Eye Laser L (Industrial 3D camera) FOV: 1250 × 1460 @ 1.5 m; 2500 × 2890 @ 3 m Resolution: 2048 × 1536 (3 MP) Accuracy: 1.0 mm @ 2 m Scan time: 0.9–1.3 s Recommended scanning distance: 1.5–3 m Mech-Viz Intelligent Programming Environment: robot programming tool Hyundai Robotics HDR50-22 (HH050) Repeatability: ±0.06 mm |
|---|---|
| Peripherals | Tooling Vacuum gripper 3D Vision Mech-Eye Laser L (FOV: 1250 × 1460 @ 1.5 m; 2500 × 2890 @ 3 m, Resolution: 2048 × 1536 (3 MP), Accuracy: 1.0 mm @ 2 m, Scan time: 0.9–1.3 s, Recommended scanning distance: 1.5–3 m, Mech-Viz Intelligent Programming Environment: robot programming tool) Peripheral Equipment Robot base Vision mounting stand Box infeed stand Pallet fixing guide |
Workflow
| STEP 1. | Scan available pallet stacking space using 3D vision |
|---|---|
| STEP 2. | Pick each box and place it into the remaining pallet space based on its size |
| STEP 3. | Repeat until palletizing is complete |
※ The content provided by Bigwave Robotics is protected under U.S. and Canadian copyright and intellectual property laws. Unauthorized reproduction, distribution, or use of this content is strictly prohibited.