Features
High-Dimensional Perception-Based Automation A robot system capable of real-time situational judgment and strategy formulation, rather than simple repetitive motions. Implementation of a reinforcement learning model that enables trajectory prediction even within limited visibility and sensor noise.
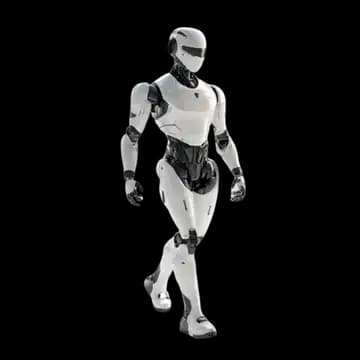
Full-Body Physical Intelligence Implementation The robot performs agile movements by organically combining its torso, legs, and arms. Autonomous selection of the optimal movement strategy based on the shuttlecock's position, speed, and airtime.
Autonomous Return and Preparation for Next Play Implementation of actions that include moving to the center of the court after striking to prepare for the next attack. An advanced control system that mimics the human-like motion flow required in sports competitions.
Results
| Client Feedback | The ETH Zurich research team stated, "ANYmal-D has surpassed the limitations of conventional robots by implementing true Physical Intelligence that perceives and reacts to physical situations." They evaluated it as "a turning point that proves the potential for robots that move and react like humans in various fields such as sports, disaster rescue, and military training."
|
|---|
※ The content provided by Bigwave Robotics is protected under U.S. and Canadian copyright and intellectual property laws. Unauthorized reproduction, distribution, or use of this content is strictly prohibited.
Recommended Use Cases

Indoor Logistics Transport and Loading Using VisionNav VNPA15🏗️
Process Overview This case study showcases a logistics automation solution that uses VisionNav's VNPA15 autonomous mobile robot (AMR) to automate the transport and loading/stacking of packaged products in indoor material-handling operations. Built on robust safety functions, the solution minimizes changes to existing workflows while enabling unattended load/unload tasks, and provides effective monitoring and control of real-time operations.

AMR Logistics Robots Introduced to Manufacturing Factory ✨ Logistics Automation that Quickly Resolves Even 1 Ton of Waste Derbris (2 KUKA KMP 1500P Logistics Robots)
Process Overview This case study demonstrates the installation of a KUKA KMP 1500P logistics robot at Bigwave Robotics (Marosol) to transport rollers and scrap debris within the space manufacturing facility. The KMP 1500P autonomously handles up to 1 ton of scrap debris over a 1.2 km distance and automatically transports heavy-duty roller modules weighing up to 1 ton. Furthermore, sensors embedded in the KMP 1500P enabled the development of an unmanned system capable of safely transporting heavy-duty materials. Project Background and Purpose Automated unmanned transport using autonomous robots Robots perform simple, repetitive tasks Safe operation of heavy-duty products using various sensors Remote control and monitoring using SOLlink

Full Automation of Injection Molding Line Logistics with AMR Logistics Robots
Process Overview This case study demonstrates an inline logistics solution that utilizes the Yujin Robot GoCart180 and an upper conveyor module to automatically transport plastic injection products from the injection molding machine to the shipping facility. By developing a conveyor module tailored to the customer's production line, we automated product loading and unloading, achieving complete automation throughout the entire inline transport process without operator intervention. Warranty Period 1 Year Performance Year 2023 Project Duration Need for consultation Project Background and Objectives Injection molding manufacturing in-line labor shortage Factory operations are disrupted due to difficulties securing workers Workers avoid work due to the risk of musculoskeletal disorders and industrial accidents
Features
High-Dimensional Perception-Based Automation A robot system capable of real-time situational judgment and strategy formulation, rather than simple repetitive motions. Implementation of a reinforcement learning model that enables trajectory prediction even within limited visibility and sensor noise.
Full-Body Physical Intelligence Implementation The robot performs agile movements by organically combining its torso, legs, and arms. Autonomous selection of the optimal movement strategy based on the shuttlecock's position, speed, and airtime.
Autonomous Return and Preparation for Next Play Implementation of actions that include moving to the center of the court after striking to prepare for the next attack. An advanced control system that mimics the human-like motion flow required in sports competitions.
Results
| Client Feedback | The ETH Zurich research team stated, "ANYmal-D has surpassed the limitations of conventional robots by implementing true Physical Intelligence that perceives and reacts to physical situations." They evaluated it as "a turning point that proves the potential for robots that move and react like humans in various fields such as sports, disaster rescue, and military training."
|
|---|
※ The content provided by Bigwave Robotics is protected under U.S. and Canadian copyright and intellectual property laws. Unauthorized reproduction, distribution, or use of this content is strictly prohibited.
Related Use Cases
Indoor Logistics Transport and Loading Using VisionNav VNPA15🏗️
AMR Logistics Robots Introduced to Manufacturing Factory ✨ Logistics Automation that Quickly Resolves Even 1 Ton of Waste Derbris (2 KUKA KMP 1500P Logistics Robots)