Process Overview
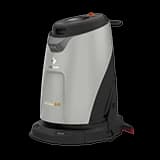
This is a case study of Bigwave Robotics (Marosol) installing the SC50 cleaning robot for factory cleaning management. Using the SC50, they implemented an in-house automated cleaning system, leveraging its outstanding cleaning performance and scheduling capabilities to operate an unmanned, automated cleaning system.
Warranty Period
- 1 year
Performance Year
- 2023
Project Duration
- 1 week
Project Background and Objectives
- Real-time cleaning in challenging environments, such as oil and cutting fluids
- Cleaning schedule planning considering the worker's working hours
- Unmanned cleaning using autonomous driving, cameras, and sensors
- Cleaning robots that clean at set times
- Manual cleaning mode for cleaning only the areas needed
- Increased cleaning efficiency through division of labor with cleaning personnel
- Remote control using SOLlink
Components
| Robot | Gausium cleaning robot SC50 |
|---|
Workflow
| STEP 1. | Select a designated cleaning area. |
|---|---|
| STEP 2. | Set the simple cleaning mode (wet) |
| STEP 3. | Start cleaning |
| STEP 4. | Return to the charging station after completing the task |
| STEP 5. | Set the desired cleaning schedule |
| STEP 6. | Start cleaning |
| STEP 7. | Return to the charging station after completing the task |
※ The content provided by Bigwave Robotics is protected under U.S. and Canadian copyright and intellectual property laws. Unauthorized reproduction, distribution, or use of this content is strictly prohibited.
Recommended Use Cases

Cleanliness Management using Gausium SC50 - Osstem Implant Production Plant
This is a case where Big Wave Robotics (Marosol) introduced the Scrubber50 cleaning robot to the Osstem Implant production plant for Cleaning Robot operations. Gausium Scrubber50 features a work process that is easy to use even for first-time robot users, excellent productivity, and various modes—including scrubbing, sweeping, and mopping—allowing for appropriate use depending on the situation. It is recommended for work environments requiring cleanliness management against dust and particles.

Shopping Center Cleanliness Management Using Gausium Phantas - Pangyo Familles Mall Edition
This is an example of Bigwave Robotics (Marosol) introducing the Phantas cleaning robot for maintenance operations at Pangyo Pameus Mall. The Gausium Phantas features an operation process that is easy for even first-time users to manage, along with excellent cleaning performance. It is capable of both dry and wet cleaning and offers various modes for appropriate use depending on the situation. It cleans by autonomously moving along a designated path with simple operation, requiring no separate intervention from the customer.

Hyundai Rotem Wearable Robot H-FrameP (Motor-powered Type)
H-FrameP, a wearable robot developed by Hyundai Rotem, is a solution that minimizes worker fatigue by significantly reducing the workload through assistive power utilizing motors. Shoulder height, waist length, and arm length can be adjusted to suit the user, allowing anyone, regardless of age or gender, to wear and use it.
Process Overview
This is a case study of Bigwave Robotics (Marosol) installing the SC50 cleaning robot for factory cleaning management. Using the SC50, they implemented an in-house automated cleaning system, leveraging its outstanding cleaning performance and scheduling capabilities to operate an unmanned, automated cleaning system.
Warranty Period
- 1 year
Performance Year
- 2023
Project Duration
- 1 week
Project Background and Objectives
- Real-time cleaning in challenging environments, such as oil and cutting fluids
- Cleaning schedule planning considering the worker's working hours
- Unmanned cleaning using autonomous driving, cameras, and sensors
- Cleaning robots that clean at set times
- Manual cleaning mode for cleaning only the areas needed
- Increased cleaning efficiency through division of labor with cleaning personnel
- Remote control using SOLlink
Components
| Robot | Gausium cleaning robot SC50 |
|---|
Workflow
| STEP 1. | Select a designated cleaning area. |
|---|---|
| STEP 2. | Set the simple cleaning mode (wet) |
| STEP 3. | Start cleaning |
| STEP 4. | Return to the charging station after completing the task |
| STEP 5. | Set the desired cleaning schedule |
| STEP 6. | Start cleaning |
| STEP 7. | Return to the charging station after completing the task |
※ The content provided by Bigwave Robotics is protected under U.S. and Canadian copyright and intellectual property laws. Unauthorized reproduction, distribution, or use of this content is strictly prohibited.
Related Use Cases
Cleanliness Management using Gausium SC50 - Osstem Implant Production Plant
Shopping Center Cleanliness Management Using Gausium Phantas - Pangyo Familles Mall Edition